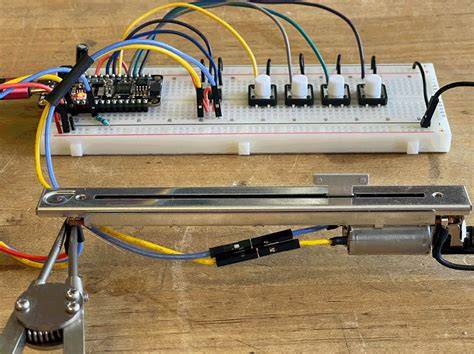
The fader used was an Alps RSA0N11M9A0J. The first thing we can try to test the motor is to supply it with 9V. The device that we need is called an H-Bridge. From Wikipedia: “An H-bridge is an electronic circuit that enables a voltage to be applied across a load in either direction. We will use 2 control pins, 2 output pins, a chip power in, a motor power pin and ground, depending of control pins, the motor will either go forwards, backwards, or it will stop. Up to this point, we will use a potentiometer for testing our circuit.
To build a motorised fader MIDI controller, you begin with understanding the core components: a motor, a motor driver (H-bridge), a control signal path, MIDI interface, and a user-adjustable fader for tactile input. The Alps RSA0N11M9A0J provides a compact motorized fader mechanism whose performance depends on precise control of voltage and direction. The H-bridge serves as a bidirectional switch, allowing the motor to rotate in both directions and to halt when needed. Using two control pins, two output pins, a power supply for the chip, and a separate motor supply, you can drive the motor in forward or reverse while keeping logic ground common.
For a safe initial test, supply the motor with 9V to evaluate its operation without load. If the motor responds correctly, the next step is to integrate the H-bridge into a controllable loop. The general testing approach includes applying a PWM (pulse-width modulation) signal from a microcontroller to the H-bridge control inputs. PWM allows smooth speed control and precise stopping behavior, which is essential for a reliable motorised fader. In parallel, a potentiometer can be used as a simple analog input to simulate user movement and verify the translation of physical position to MIDI data. This setup helps validate the basic motor response before adding the MIDI layer.
The MIDI interface converts control changes from the fader position into standard MIDI CC messages. A common configuration maps the fader’s position to a specific CC number, with full travel corresponding to the maximum CC value (typically 0-127). The firmware or microcontroller can read the potentiometer position, map it to the MIDI range, and then drive the H-bridge to position the Alps RSA0N11M9A0J motor accordingly. For a robust project, include end stops to prevent the fader from over-travel, and implement soft-start and soft-stop to minimize mechanical stress and audible noise.
Key considerations for a reliable motorised fader build include power management, noise isolation, and protection diodes for the motor. The 9V test is useful, but in a finished device you may use a regulated 5-12V supply depending on motor specifications and vendor recommendations. The H-Bridge must handle the motor’s stall current; otherwise, you risk overheating or damage. If possible, measure current draw under expected load and select a driver with adequate headroom. In addition, ensure common ground between the microcontroller, MIDI circuitry, and motor driver to avoid ground loops that could cause erratic behavior.
When wiring, keep the motor wires as short as possible to reduce inductive kick and EMI. Use decoupling capacitors close to the motor and the H-bridge power pins to stabilize supply fluctuations during rapid motor movements. Implement safety features, such as a software timeout in case of motor stall or loss of control signal, and always test in a controlled, safe environment before attaching the assembly to the enclosure or the user-facing panel.
Beyond basic testing, the Alps RSA0N11M9A0J motorized fader can be integrated into a larger control surface with multiple faders, each wired to dedicated H-bridges and MIDI channels. A well-designed firmware layer translates fader positions into accurate MIDI messages while providing calibration routines to compensate for mechanical tolerances between units. Logging and diagnostic feedback can help tune the response curve, motor speed, and positioning accuracy over time. A thoughtful enclosure design reduces mechanical play and improves the tactile feel of the fader, enhancing the musical usability of the controller.
In summary, the initial testing path starts with supplying the motor at 9V and observing directional control via an H-bridge. From there, a potentiometer provides a simple analog input for validating the control loop, followed by PWM-based motor drive, MIDI mapping, and careful attention to power, protection, and mechanical design. This sequence yields a functional, reliable motorised fader MIDI controller built around the Alps RSA0N11M9A0J and a robust H-bridge solution.
MA2 - FREE! How to use faders on MIDI device on GrandMA2?
Table: Key parameters for a typical motorized fader test setup
| Component | Role | Notes |
|---|---|---|
| Alps RSA0N11M9A0J | Motorized fader | Rotational/linear motion for MIDI control |
| H-Bridge | Bidirectional motor drive | Controls motor direction via control pins |
| PWM-capable microcontroller | Control signal processor | Generates PWM for speed and position |
| MIDI interface | Output protocol | Translates fader position to MIDI CC |
| Power supply (9V test) | Initial testing | Validate motor response safely |
tags: #motorised #fader #midi #controller