Coordinate transformations of the gradient, divergence, and curl are essential when problems exhibit cylindrical symmetry. Cartesian coordinates are not always the most efficient framework, so transforming to cylindrical coordinates-where distance along the radial direction is ρ and the angular direction is φ-can simplify calculations. This article assembles and reorganizes the given material to present a maximally detailed account of curl in cylindrical coordinates, while preserving the original wording of the relevant sentences.
Del Operator and Cylindrical Coordinates
The del operator in Cartesian coordinates is written as follows: The del operator in Cartesian coordinates. Each term in the del operator represents the rate of change along three mutually orthogonal and normalized directions. (x, y, z) are the spatial variables in Cartesian coordinates. With these three variables, we can describe any position and vector in space. However, using Cartesian coordinates to calculate problems with spherical symmetry or cylindrical symmetry is very inefficient. For this reason, we need to introduce new coordinate representations.
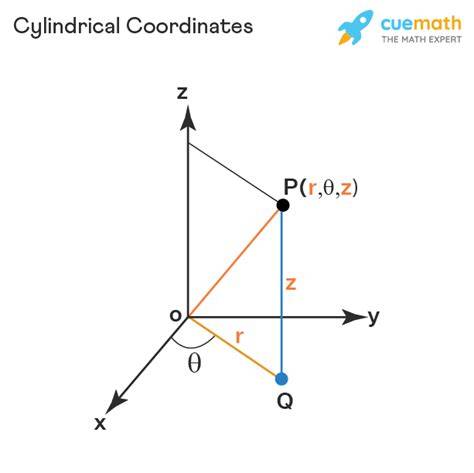
Figure (1) shows the relationship between cylindrical coordinates and Cartesian coordinates. Before performing the coordinate transformation, it is useful to first guess what the expression in cylindrical coordinates might look like. For example, if we imitate the Cartesian form, we may obtain the following result: Equation (2): A guessed form of the del operator in cylindrical coordinates. Note that each term in the del operator describes the change in distance along that direction. However, in the expression above, the denominator of the φ term is dimensionless. To make the units correct, we rewrite the expression as: Equation (3): The del operator in cylindrical coordinates. Here, h is the metric coefficient, which describes how distance changes along the angular direction. Once h is determined, the transformation of the del operator from Cartesian coordinates to cylindrical coordinates is complete. Determining h is straightforward. If the position moves along the φ direction, the change in distance is the arc length along the cylinder, which is ρdφ. Therefore, the metric coefficient is: Equation (4): The metric coefficient. Finally, we obtain the correct form of the del operator in cylindrical coordinates: Equation (5): The correct form of the del operator in cylindrical coordinates.
By the same reasoning, the del operator in spherical coordinates can be derived using the same method. First, the relationship between spherical coordinates and Cartesian coordinates is given as follows: Figure (2): Spherical coordinates. First, the del operator in spherical coordinates is written in a generalized form as: Equation (6): A guessed form of the del operator in spherical coordinates. To calculate the metric coefficients, we use the following figure to aid visualization: Figure (3): Projections of coordinates onto different planes. From this, we can see that the change along the r direction is simply dr. The change along the θ direction is the arc length obtained by rotating an angle dθ with radius r, which is rdθ. The change along the φ direction is the arc length obtained by first projecting the radius onto the xy-plane and then rotating by dφ, which is rsinθdφ. Therefore, the del operator in spherical coordinates is: Equation (7): The correct form of the del operator in spherical coordinates.
Gradient, Divergence, and Curl in Cylindrical Coordinates
The next subsection concerns how the basis unit vectors behave under changes of coordinates. If a vector is a constant vector, it remains parallel to the original one under translations. If the vector after the change is not parallel to the original, then the vector depends on those variables. In that case, it cannot be taken outside the derivative directly when performing differentiation.
Gradient: We start from the simplest operation, the gradient. When the del operator acts on a scalar field F, it produces the gradient of that field. In Cartesian coordinates, it is written as: Equation (8): The gradient in Cartesian coordinates. Because the gradient operates on a scalar field, the partial derivatives do not introduce any additional complications. By the same reasoning, in cylindrical and spherical coordinates, the expressions are obtained simply by applying the transformed del operator: Equation (9): The gradient in cylindrical coordinates.
Divergence: Next, we consider divergence. Starting from the Cartesian coordinate system, we apply the del operator to a vector field A and take the divergence: Equation (10): Expansion of the divergence in Cartesian coordinates. In Cartesian coordinates, the unit vectors are constant; the divergence can be written as Equation (11): The divergence in Cartesian coordinates. However, in cylindrical coordinates, the basis vectors are not constant vectors. Therefore, we must treat the partial derivatives of these basis vectors separately. We start with the radial unit vector ρ. First, we determine which variables ρ depends on. From the cylindrical-coordinate diagram introduced earlier, we see that ρ changes only with the angle φ. Therefore, we only need to consider the partial derivative with respect to φ. To compute this derivative, we change the angle by an amount dφ and observe how ρ changes. Figure (4): The change of ρ w.r.t dφ. Because dφ is infinitesimal, the angle between dρ and ρ(φ) is a right angle (imagine overlapping ρ(φ) and ρ(φ + dφ)). Using these geometric relations, we rewrite dρ in the form of a magnitude times a unit vector to facilitate later calculations: Equation (12): Infinitesimal change of the unit vector. The unit vector φ also changes only with the angle. We apply the same method and draw the change of φ when the angle varies: Figure (5): Translation of the φ unit vector. The direction of dφ is obtained by rotating ρ clockwise by two successive 90-degree rotations, so the direction is -ρ. Similarly, we rewrite dφ as: Equation (13): Rewriting the change of the unit vector. Next, we calculate the divergence of the vector field A in cylindrical coordinates: Equation (14): Calculation of the divergence in cylindrical coordinates. Expanding this expression gives: Equation (15): Expansion of Equation (14). Because ρ = ρ(φ) and φ = φ(φ), we only need to pay attention to partial derivatives with respect to the angle. The results of these partial derivatives can be obtained from the total differentials derived earlier: Equation (16): Partial derivatives of the unit vectors. Therefore, the divergence can be simplified to: Equation (17): The divergence in cylindrical coordinates. In this way, we obtain the expression for divergence in cylindrical coordinates. The key point lies in handling the partial derivatives of the unit vectors; the remaining steps are just algebraic rearrangement and simplification.
For spherical coordinates, we ask which variables the basis vectors depend on. In spherical coordinates, there are two angular variables, θ and φ. The radial direction r changes with r, but the directions of r and θ change with θ, while φ depends on φ. This is illustrated in Figure (6): Spherical-coordinate cross section. The unit vector φ is always perpendicular to the plane spanned by the radial vector and its projection onto the xy-plane. Even when rotating along θ, this normal vector is only translated. A common property of all these basis vectors is that they do not change with r. Therefore: Equation (18): Variables on which each unit vector depends. This means that during the divergence operation, the basis vectors cannot be treated as constant vectors when taking partial derivatives with respect to θ and φ. To compute these derivatives, we again consider how the unit vectors change. Starting with the radial unit vector r, the changes dr under variations of θ and φ are shown in the figure below: Figure (7): Change of the radial unit vector. Note that when φ changes, the change in the radial vector must be projected onto the xy-plane. We therefore write dr in the following form to include all these effects: Equation (19): Total differential of the radial unit vector. For dθ, the situation is similar to the cylindrical case. When θ changes, the direction is -r. Changes along φ also require projection onto the xy-plane, as shown: Figure (8): Relation between the θ and φ unit vectors. Thus, we obtain: Equation (20): Change of the θ unit vector. The change dφ requires more visual aid. We first analyze its direction using Figure (9): Direction analysis of dφ. After a preliminary analysis, we find that dφ does not directly correspond to any single known unit vector. This is not a problem, because any vector can always be expressed as a linear combination of the basis vectors through projection. The coefficients of this linear combination are given in Figure (10): Decomposition of the φ unit vector: dφ = v1 + v2. In accordance with Fig. (9), the magnitude of dφ is equal to dφ. Projecting this vector onto the -r and -θ directions then determines its orientation; therefore, it can be expressed as: Equation (21): Change of the dφ unit vector. Finally, we can start computing the divergence in spherical coordinates: Equation (22): Expansion of the divergence in spherical coordinates. Using the total differentials of the basis unit vectors, we obtain the partial-derivative terms required for the calculation above: Equation (23): Partial derivatives of the unit vectors. Using these results, we continue the calculation and obtain the divergence in spherical coordinates: Equation (24): The divergence in spherical coordinates.
Curl in Cylindrical Coordinates
Do not worry - the calculation of the curl only requires following the rules and organizing the expressions, because all the necessary partial derivatives have already been computed. First, the curl in Cartesian coordinates is written as: Equation (25): The curl in Cartesian coordinates. For cylindrical coordinates, we start from the basic definition rather than the determinant form, so that the difference from the Cartesian case becomes clear: Equation (26): Expansion of the curl in cylindrical coordinates. Using the partial derivatives calculated earlier and the vector cross products, we obtain: Equation (27): The curl in cylindrical coordinates. This can be simplified into a determinant form: Equation (28): Determinant representation. From this, we can see that if we want to use the determinant form, the corresponding metric coefficients must be included in front of the basis vectors and the components of the vector field, and the determinant must be multiplied by the reciprocal of the product of all metric coefficients.
Using this rule, the curl in spherical coordinates can be written directly as: Equation (29): Determinant representation of the curl in spherical coordinates. Through the coordinate transformations of the gradient, divergence, and curl, we can see that vector differentials in coordinate systems other than Cartesian coordinates cannot be treated as constants. Because the del operator contains partial derivatives with respect to each coordinate direction, extra care must be taken when performing these operations.
Practical Notes and Examples
- The azimuthal angle in cylindrical coordinates introduces a metric coefficient ρ, which adjusts the φ-derivative to produce the correct physical change along the angular direction.
- When evaluating curl in cylindrical coordinates, the first principles approach clarifies how basis vectors depend on φ and how this dependence enters the cross-product structure.
- Determinant forms for curl in non-Cartesian coordinates must incorporate metric coefficients in front of the basis vectors and components, and the determinant must be scaled by the reciprocal of the product of all metric coefficients.
Summary of Key Forms
- Curl in Cylindrical Coordinates: derived from the cylindrical-del operator and the cross product with the vector field, accounting for metric coefficients.
- Curl in Spherical Coordinates: can be expressed in a determinant form with appropriate metric factors to ensure correctness.
how to write curl of a vector in spherical polar coordinate (Tricks)
tags: #curl #in #cylindrical #coordinates